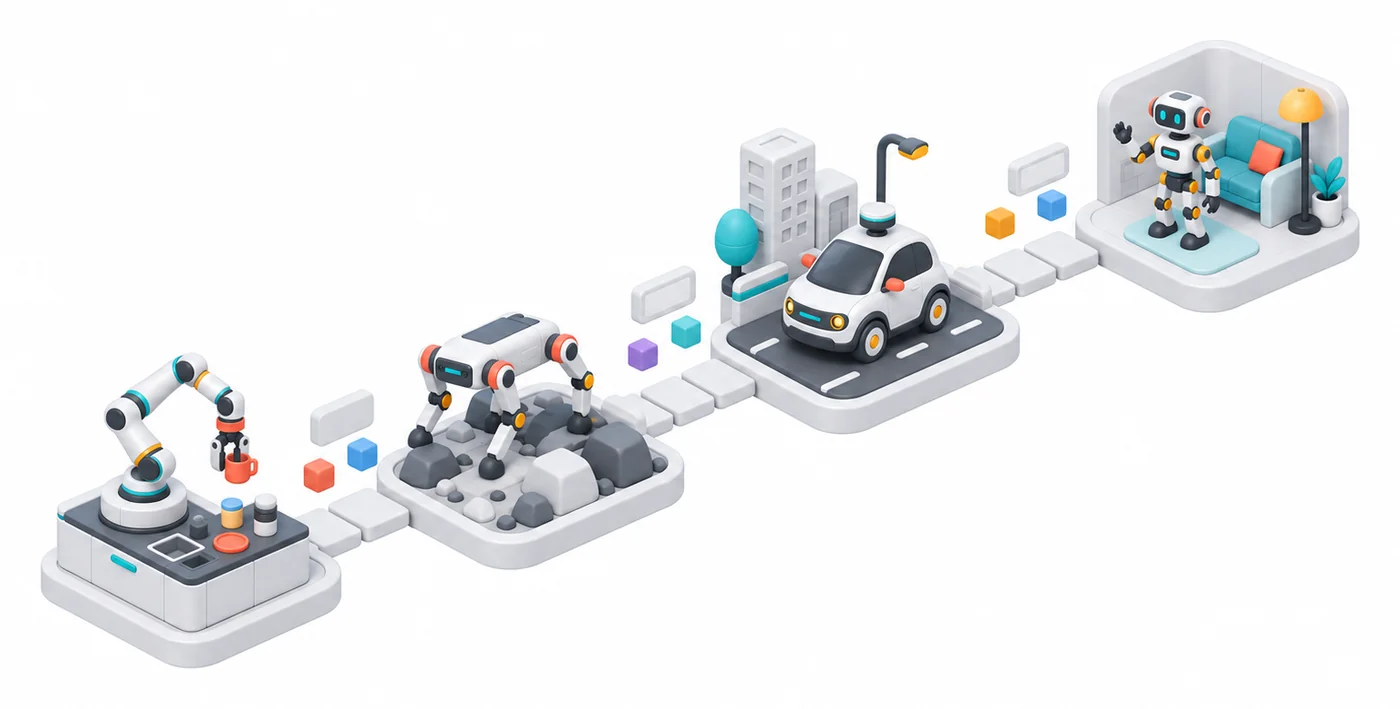
Figure 1a
Abstract
Section 1 and Figure 1
The field at a glance
Figure 1b
Forgetting under plain sequential fine-tuning
Section 2
Problem formulation
Operational definition, Section 2.1
Figure 2, Sections 3 to 9
Taxonomy of the reviewed literature
Section 1.3 and the evidence tables
Evidence explorer
Section 1.4
Seven propositions
Section 3 and Table 4
Algorithmic mechanisms
Section 4
Foundation models and self-improving agents
Studies with foundation-model learners
Coded studies whose learner builds on a pretrained VLA, VLM or LLM, or that Table 5 lists. Table 5 covers those discussed in Section 4; the others appear in Tables 6 to 11. Each entry names its table.
Self-improving agents
Sections 5 to 8
Tasks, environments, embodiments, and feedback
One tab per section of the review: its opening argument, the authors’ assessment, its figure where there is one, and a profile of the coded studies filed under that axis or, for Section 8, under feedback.
Sections 9.1 and 9.2, Tables 12 and 13
Benchmarks and resources
Sections 9.3 to 9.6
A difficulty hierarchy for evaluation
Sections 10 and 11, Table 14
Open problems and research programs
Conclusion
Figures
The figures of the review. Select one to open it at full resolution with its caption; the arrow keys move between figures.
Library
The works cited in the full version of the review, with DOI or arXiv links where the bibliography records them, and BibTeX entries.
Citation
If you use this review, please cite it as follows.
@misc{li2026continual,
  title  = {{Continual Learning for Embodied AI: A Comprehensive Review
            and Perspective}},
  author = {Li, Zirui and Mao, Zhiqi and Yang, Haohan and Cai, Yuxin and
            Yang, Shuo and Huang, Heye and Jia, Jindou and
            Lin, Yunlong and Ren, Yangang and Ji, Yuan and
            Song, Ziying and Huang, Dongyue and Huang, Yanjun and
            Cavallaro, Andrea and Liu, Ziwei and Lv, Chen},
  year   = {2026},
  url    = {https://lzrbit.github.io/cl-eai/},
  note   = {Preprint}
}